A Synchronous Motor converts electrical energy into steady mechanical rotation. Its rotor locks onto the rotating magnetic field created by the stator. Once synchronized, it turns at the exact speed set by supply frequency and pole count. There is almost no slip during normal operation. That detail separates it from an induction motor.
Electrical-machines author Stephen J. Chapman states, “A synchronous motor runs at synchronous speed.” This concise idea explains its main advantage. A four-pole motor on a 50-hertz supply rotates at 1,500 revolutions per minute. On a 60-hertz supply, the same motor reaches 1,800 revolutions per minute. The rotor may use permanent magnets, a wound field, or reluctance-based geometry. Each design produces a different balance of efficiency, cost, starting ability, and control complexity.
The working process deserves a closer look. The stator establishes a rotating magnetic field. The rotor must then reach, or approach, that field’s speed before magnetic locking occurs. Many traditional designs cannot start directly from a standstill. They need damper windings, an auxiliary drive, or an electronic inverter. Modern permanent-magnet versions often start smoothly through variable-frequency drives. In a factory, this can mean stable conveyor speed, accurate pump control, and improved power factor. The explanation is not perfectly simple. Load changes, heating, harmonics, and loss of synchronism still matter. Understanding these practical limits makes the Synchronous Motor more than a textbook diagram. It becomes a precise machine with real operating conditions.
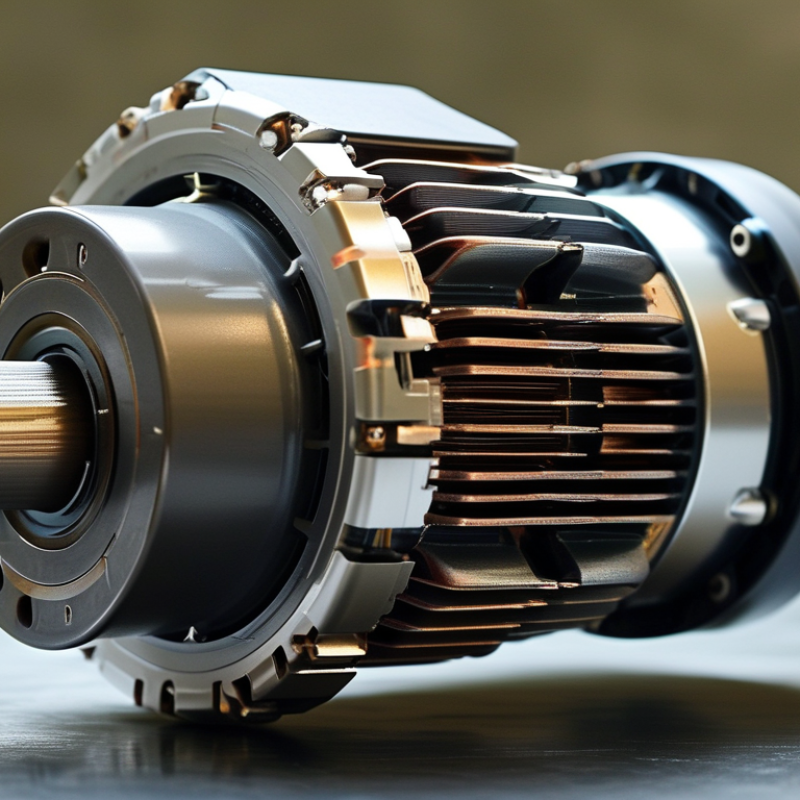
A synchronous motor converts electrical energy into mechanical rotation at a fixed speed. Its stator creates a rotating magnetic field. The rotor follows and locks to that field. It does not normally slip during steady operation.
The speed follows this formula: synchronous speed = 120 × frequency ÷ pole count. At 50 hertz, a four-pole motor runs at 1,500 revolutions per minute. The rotor may use permanent magnets, direct-current excitation, or magnetic reluctance. Starting needs special support, such as a variable-frequency drive or damper winding. Without it, the rotor may simply vibrate instead of turning. That detail is often overlooked.
When the shaft load increases, the rotor develops a larger torque angle while maintaining nearly constant speed. If the angle becomes excessive, the motor can lose synchronism and stop. Technicians therefore check current, vibration, temperature, cooling airflow, and power factor during commissioning. A nameplate reading alone is insufficient. The International Energy Agency’s Energy Efficiency 2023 report estimates that electric motor systems consume about 50% of global electricity. The U.S. Department of Energy’s Motor Systems Market Assessment places motor use near 70% of industrial electricity consumption in the United States. These figures explain the motor’s importance, but they can hide local conditions. A lightly loaded motor may waste energy, even when its efficiency rating looks impressive. A precise calculation can still support a poor decision.
The chart shows the ideal synchronous speed of a four-pole synchronous motor at different supply frequencies. Synchronous speed is calculated using Ns = 120f / P, where f is frequency in hertz and P is the number of poles. The rotor rotates at the same speed as the rotating magnetic field.
Because the rotor remains locked to the rotating magnetic field, a synchronous motor operates at constant speed under normal load conditions, with speed determined primarily by supply frequency and pole count.
A synchronous motor converts electrical energy into steady mechanical rotation. Unlike an induction motor, its rotor turns at the same speed as the rotating magnetic field. This relationship depends on carefully matched magnetic poles and frequency.
The stator forms the stationary outer section. Its laminated steel core reduces energy losses, while copper windings create the rotating magnetic field. Insulation around each winding prevents short circuits and withstands heat. The rotor sits inside the stator with a small, even air gap. It may contain permanent magnets or field windings supplied with direct current. These parts produce the magnetic poles that lock onto the stator field.
The shaft carries torque to the driven machine. Bearings support it and control vibration, although small alignment errors can cause noticeable noise. A rigid frame holds the assembly together and helps transfer heat away from the windings. Cooling fans, air passages, or external heat exchangers manage operating temperature. Large motors may also include an exciter, position sensor, and control panel. The sensor checks rotor position before the controller adjusts current. Starting can be difficult without proper assistance, because the rotor does not naturally accelerate like an induction motor. A technician should inspect insulation, bearing condition, air-gap clearance, and terminal tightness during maintenance. The design is efficient, but not maintenance-free. Dust, heat, and poor alignment still reduce reliability.
| Main Component | Construction and Typical Materials | Primary Role | Operating Principle | Important Design Considerations |
|---|---|---|---|---|
| Stator Core | Laminated electrical-steel sheets assembled into a cylindrical core | Provides a low-reluctance path for magnetic flux and supports the stator winding | Alternating magnetic flux is guided around the air gap with reduced eddy-current loss | Lamination thickness, core loss, mechanical stiffness, and ventilation affect efficiency and temperature rise |
| Stator Winding | Insulated copper conductors placed in slots and connected as a multiphase winding | Creates the rotating magnetic field that drives the rotor | Multiphase currents displaced in time produce a magnetic field rotating at synchronous speed | Conductor size, insulation class, winding distribution, and current density determine heating and torque capability |
| Rotor | Solid or laminated rotor structure carrying field poles, field windings, or permanent magnets | Establishes a magnetic field that locks with the stator's rotating magnetic field | Runs at the same mechanical speed as the rotating stator field once synchronism is reached | Rotor strength, magnetic balance, inertia, and allowable speed govern reliability and dynamic performance |
| Rotor Field Winding | Insulated copper coils mounted on salient-pole or cylindrical rotors | Produces controllable direct-current magnetic excitation | The rotor field interacts with the stator field to develop electromagnetic torque | Excitation level influences power factor, reactive-power exchange, and pull-out torque |
| Damper or Amortisseur Winding | Conductive bars embedded in rotor pole faces and connected by end rings | Assists starting and reduces oscillations during load changes | Induced currents produce asynchronous starting torque and damp rotor hunting after synchronization | Bar resistance and reactance affect starting torque, damping strength, and additional rotor losses |
| Air Gap | Precisely controlled clearance between the stator bore and rotor surface | Allows the rotor to rotate while coupling the stator and rotor magnetic fields | Magnetic energy crosses the gap to produce torque and maintain synchronism | A smaller uniform gap generally improves magnetic coupling, but requires tighter manufacturing tolerances |
| Shaft | Machined steel shaft connected to the rotor and external mechanical load | Transmits developed torque to the driven equipment | Rotates at synchronous speed while carrying torsional and radial loads | Diameter, keyways, balance, fatigue strength, and critical speed must match the application |
| Bearings | Rolling-element or sleeve bearings supporting the rotor shaft | Maintain rotor alignment and minimize mechanical friction | Allow stable rotation while carrying radial and, where applicable, axial forces | Lubrication, bearing load, temperature, vibration, and service life are key maintenance factors |
| Excitation System | Direct-current power source supplied through slip rings and brushes or a brushless exciter | Controls rotor field current and magnetic strength | Adjusting excitation changes the motor's internal electromotive force and reactive-power behavior | Response speed, insulation, maintenance requirements, and field forcing capability affect system performance |
| Frame and End Shields | Rigid steel or cast-metal enclosure with end brackets and mounting feet | Supports internal components, protects the motor, and transfers mounting forces | Maintains alignment and provides a structural path for vibration and operating loads | Enclosure rating, rigidity, corrosion protection, and access for inspection influence operating life |
| Cooling System | Internal fan, external fan, air passages, or liquid-based heat exchanger | Removes heat generated by copper, core, mechanical, and excitation losses | Transfers heat from active parts to surrounding air or a separate cooling medium | Cooling capacity, airflow, ambient temperature, cleanliness, and enclosure design determine thermal limits |
| Insulation System | Slot liners, conductor enamel, phase insulation, wedges, and varnish or resin | Prevents electrical shorts and isolates windings from the core and other phases | Withstands operating voltage, transient overvoltage, vibration, and thermal cycling | Thermal class, dielectric strength, moisture resistance, and partial-discharge performance are important |
| Performance Dimension | Typical Relationship or Characteristic | Practical Significance |
|---|---|---|
| Synchronous Speed | ns = 120f / P, where ns is in revolutions per minute, f is frequency in hertz, and P is the number of poles | Speed is fixed by supply frequency and pole count rather than by load within the stable operating range |
| Slip During Normal Operation | Ideally zero after the rotor reaches synchronism | The motor maintains constant speed until excessive load causes loss of synchronism |
| Starting Requirement | May require damper windings, a variable-frequency drive, or an auxiliary starting motor | A synchronous motor generally cannot self-start directly from a fixed-frequency supply without a starting strategy |
| Power Factor Control | Rotor excitation can be adjusted to operate at lagging, near-unity, or leading power factor | The motor can provide mechanical output while also helping manage reactive power in an electrical system |
| Load Stability | Stable operation is maintained while the torque angle remains within the motor's pull-out limit | Sudden overloads or disturbances can cause the rotor to fall out of synchronism |
A synchronous motor converts electrical energy into steady mechanical rotation. The International Energy Agency estimates that electric motor systems use nearly half of global electricity. This makes correct operation important, not merely theoretical.
The process begins when three-phase stator windings receive alternating current. Their currents create a rotating magnetic field inside the air gap. The field speed depends on supply frequency and pole count. For example, a four-pole motor on a 50 hertz supply produces a 1,500 revolutions-per-minute field. The rotor initially stands still. It cannot normally start by itself. A damper cage, auxiliary drive, or variable-frequency drive brings the rotor close to synchronous speed.
The rotor then receives direct-current excitation, or produces its own magnetic field through permanent magnets. Its poles pull into alignment with the stator’s rotating field. The rotor locks to that field and runs at constant speed. Load changes mainly alter the torque angle, not the average speed. If the load exceeds the pull-out limit, synchronism can fail. That detail is often overlooked. The U.S. Department of Energy has reported that motor-driven equipment consumes about 25% of U.S. electricity, so small efficiency losses can become significant. In practice, engineers check excitation, vibration, temperature, and power factor. A poorly tuned system may still run, but it wastes energy and offers little operating margin.
A synchronous motor runs at the same speed as the rotating magnetic field. Its speed follows a simple relationship: speed equals 120 times frequency divided by pole count . The rotor does not slip during normal operation. This makes the motor useful for compressors, pumps, and machines requiring steady shaft speed. However, it usually cannot start by itself. That detail is often underestimated.
Starting methods solve this limitation. A damper winding can start the rotor like an induction motor, then lock it into synchronism. A separate pony motor can accelerate the rotor before field excitation begins. A variable-frequency drive offers smoother starting by gradually raising frequency. Speed control mainly comes from changing supply frequency, while rotor excitation controls reactive power and power factor. Mechanical load still matters. Excessive load can pull the rotor out of step.
Synchronization requires correct phase sequence, frequency, voltage, and phase angle. In grid-connected systems, these values must match closely before connection. With a drive, the controller manages synchronization electronically and limits sudden current surges. Small timing errors can create vibration or high torque stress.
Tips: Check the nameplate frequency and pole count before selecting control settings. Monitor field current, bearing temperature, and vibration during commissioning. Never assume a successful start proves stable synchronization; observe the motor under changing load. A practical review may reveal overlooked wiring or tuning issues.
A synchronous motor rotates at the same speed as the stator’s rotating magnetic field. Its speed depends on supply frequency and pole count. Unlike an induction motor, it does not normally rely on slip during steady operation. Common types include wound-field, permanent-magnet, and synchronous-reluctance motors. Wound-field designs allow excitation adjustment. Permanent-magnet versions offer strong efficiency and compact size. Reluctance motors avoid rotor magnets, but their control requirements can be demanding.
These motors suit compressors, pumps, conveyors, generators, and precision equipment. Their constant speed supports stable production, especially where timing matters. They can also improve power factor when properly excited. However, many synchronous motors cannot start directly from a fixed-frequency supply. They may need a starter, variable-frequency drive, or special damper windings. Permanent magnets can raise costs and create temperature concerns. The choice is rarely obvious. A neat efficiency calculation can still miss maintenance skills, load changes, and control complexity.
Tips: Check the load’s starting torque before choosing a motor. Record speed, frequency, voltage, and duty cycle from the actual site. Leave thermal margin for dusty rooms or frequent starts. Test power-factor correction under real operating conditions. In practice, a smaller motor may run efficiently, but it can struggle during sudden load peaks. Review that risk with a qualified electrical engineer.
It converts electrical energy into mechanical rotation at a fixed operating speed. Its rotor locks with the stator’s rotating magnetic field. Slip is normally absent during steady operation.
Use this formula: synchronous speed = 120 × frequency ÷ pole count. A four-pole motor supplied at 50 hertz runs at 1,500 revolutions per minute. Frequency and pole count matter.
The rotor may not start by itself on a fixed-frequency supply. It can vibrate instead of rotating. A variable-frequency drive, starter, or damper winding can provide starting support.
The rotor develops a larger torque angle while keeping nearly constant speed. If that angle becomes excessive, the motor can lose synchronism and stop. The risk is easy to underestimate.
Common designs use permanent magnets, direct-current excitation, or magnetic reluctance. Wound-field motors allow excitation adjustment. Permanent-magnet motors are compact, while reluctance designs avoid rotor magnets.
They operate compressors, pumps, conveyors, generators, and precision equipment. Constant speed helps maintain stable production timing. Actual suitability depends on starting torque and duty cycle.
Yes, proper excitation can improve power factor. The result depends on the motor’s load and operating conditions. Test correction at the real installation, not only in a spreadsheet.
Check current, vibration, temperature, cooling airflow, speed, voltage, frequency, and power factor. Inspect performance under the actual load. A nameplate reading alone is insufficient.
Record starting torque, load changes, duty cycle, and environmental conditions first. Leave thermal margin for dust, heat, and frequent starts. A smaller motor may save energy but struggle during sudden peaks. Measure the real load.
A Synchronous Motor is an AC motor that operates at a constant speed synchronized with the frequency of its power supply. Its main components include a stator with three-phase windings, a rotor that produces a magnetic field, an air gap, bearings, and a control or excitation system. When alternating current flows through the stator, it creates a rotating magnetic field. The rotor’s magnetic field then aligns with this rotating field, allowing the motor to turn at synchronous speed without slip.
Because a Synchronous Motor is not usually self-starting, it may require an auxiliary starting mechanism, damper windings, or an electronic drive. Its speed is mainly controlled by adjusting the supply frequency, while synchronization depends on matching the rotor position and operating conditions with the rotating field. Synchronous motors may use different rotor designs and are applied in pumps, compressors, fans, industrial machinery, and power-factor correction systems. They offer constant speed, high efficiency, and improved power-factor control, but can involve higher costs, complex starting arrangements, and sensitivity to overload or loss of synchronization.
Brea Tech Micro Motor